Case 07: Fall-arrest Cutebot
Purpose
The Cutebot reverses quickly when detecting the edge of a table and goes forward after making a turn.
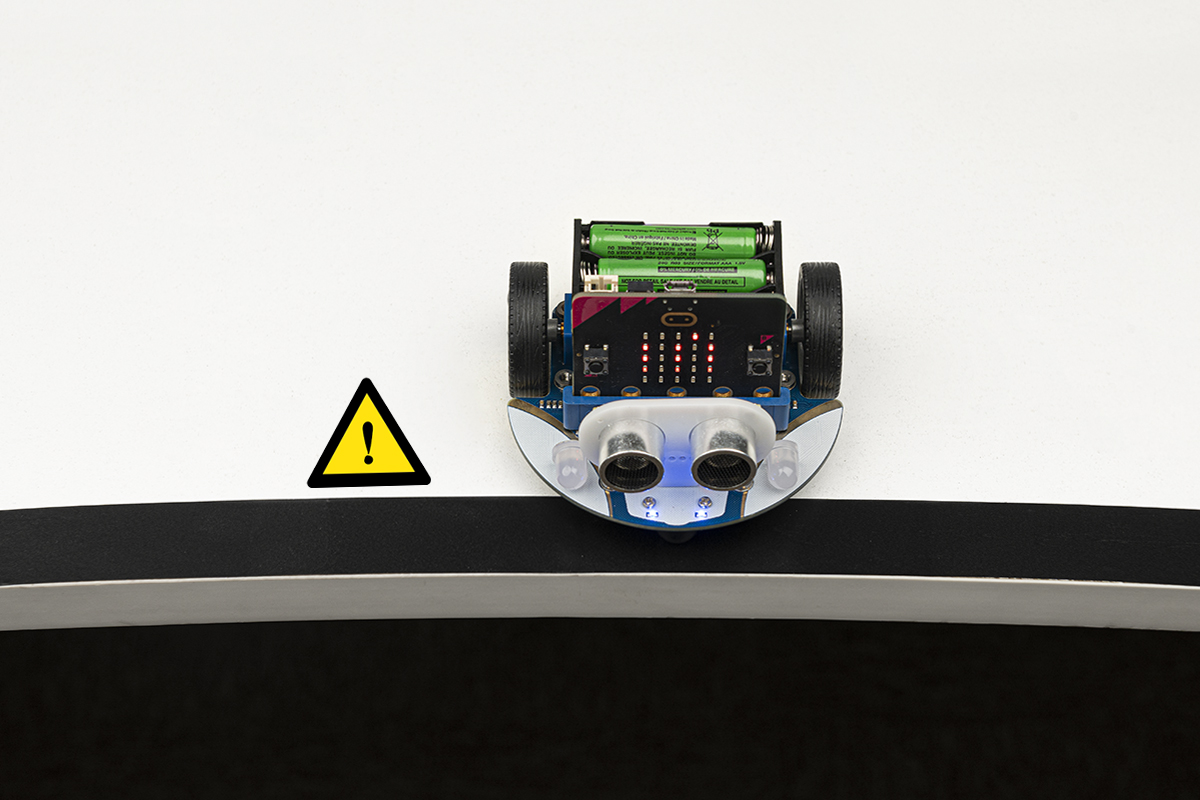
Materials
1 x Cutebot Kit
Software Platform
Programming
Step 1
Click the "Advanced" to see more choices in the MakeCode drawer.
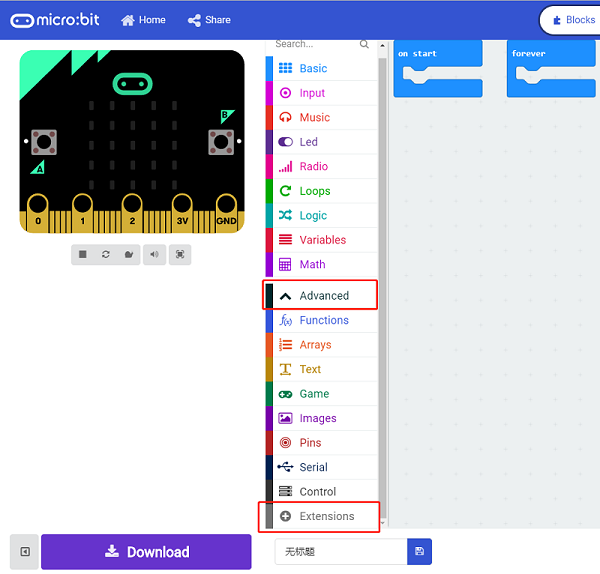
A codebase is required for Cutebot programming, click “Add Package” at the bottom of the drawer, search 'Cutebot' in the dialogue box and download it.
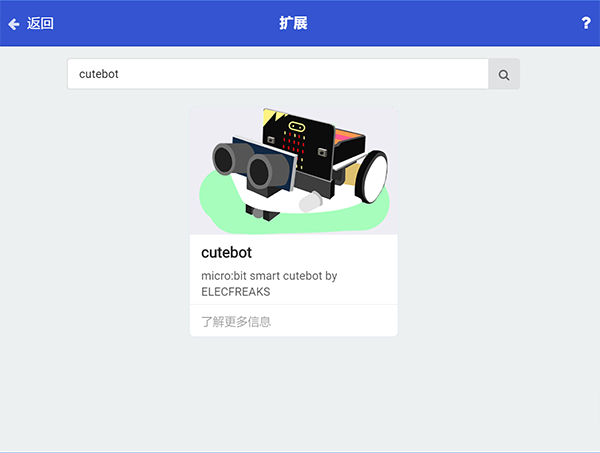
Note: If you met a tip indicating incompatibility of the codebase, you can continue with the tips or build a new project there.
Step 2
Choose "show icon" in the On start brick.
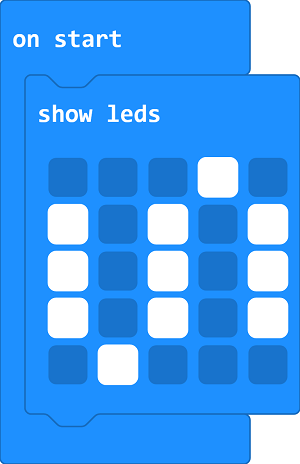
Step 3
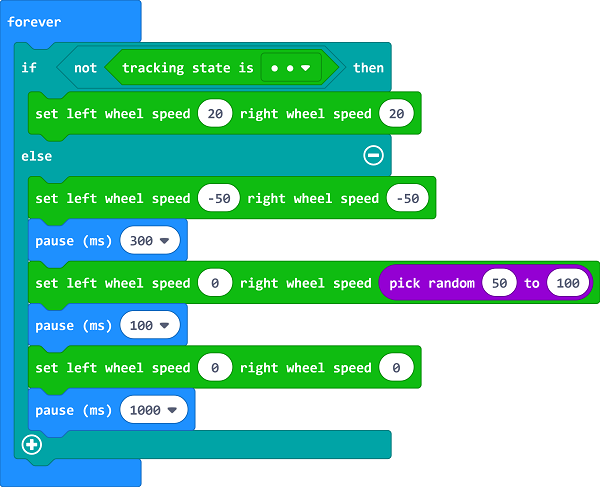
Drag if brick into forever brick and judge if both of the line-tracking sensors are detecting the edges of the black line, then set the right wheel speed to 20.
If not, set the speed of both wheels as -50 to reverse, pause 300ms and keep the left wheel still but the right wheel moves at a random speed from 50~100 and lasts 100ms.
Set the speed of both wheels to 0 and pause 1s to move forward again.
Programming
Links: https://makecode.microbit.org/_2z1hh4iEUgTY
You can also download it directly below:
Result
The Cutebot reverses quickly when detecting the edge of a table and goes forward after making a turn.