TPbot Combat 2
Purpose
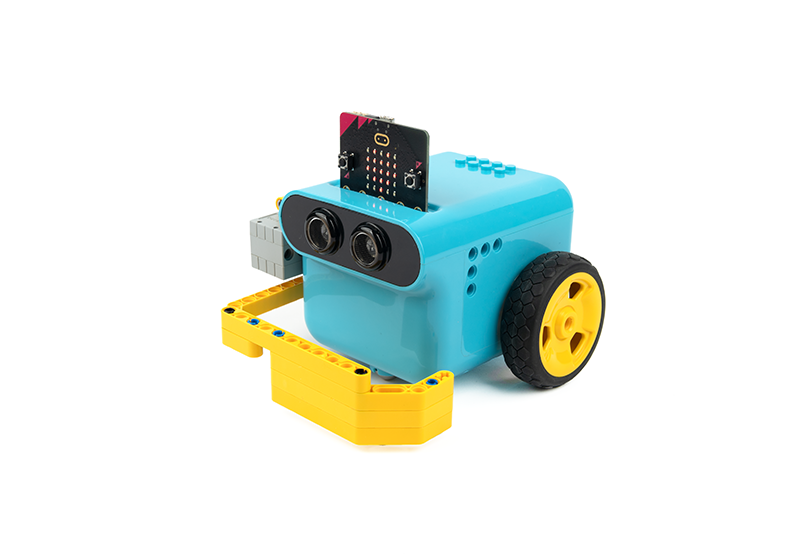
To build a combat TPBot.
Materials Requested
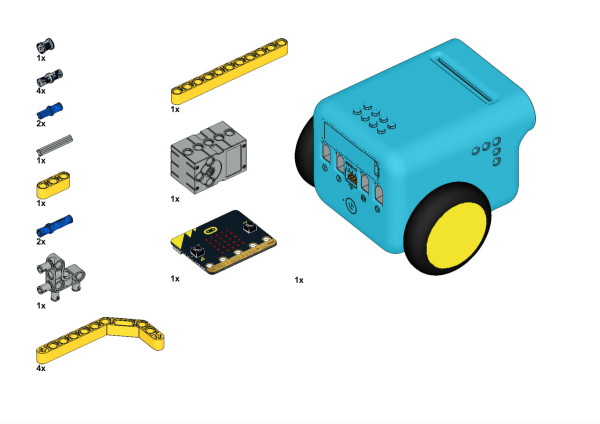
Bricks Pack
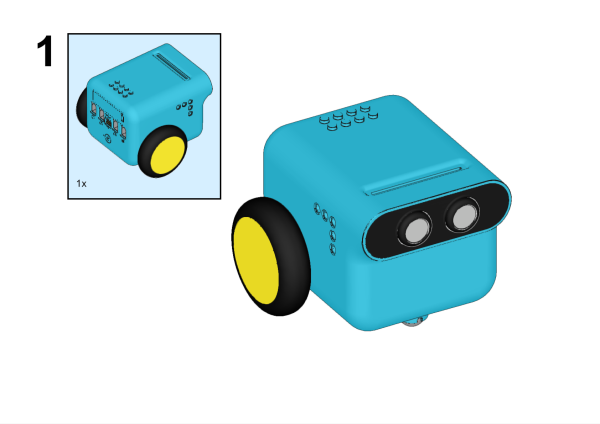
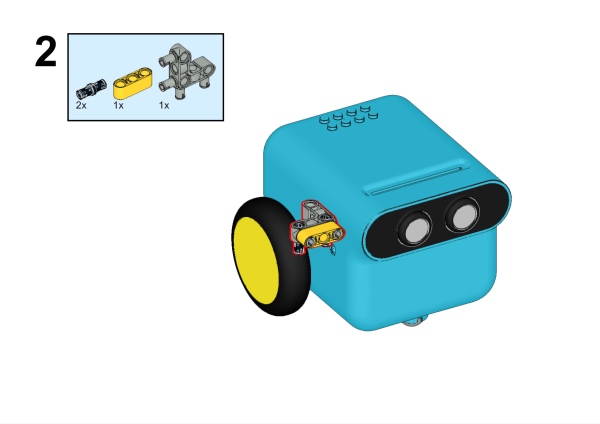
Assembly Steps
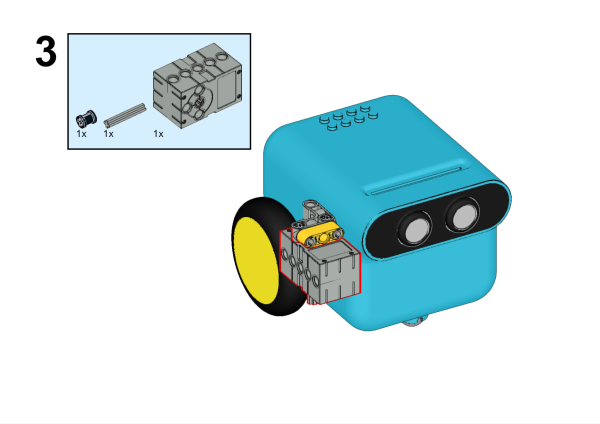
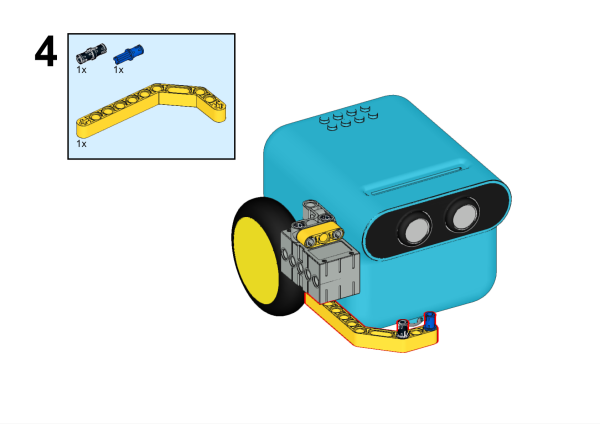
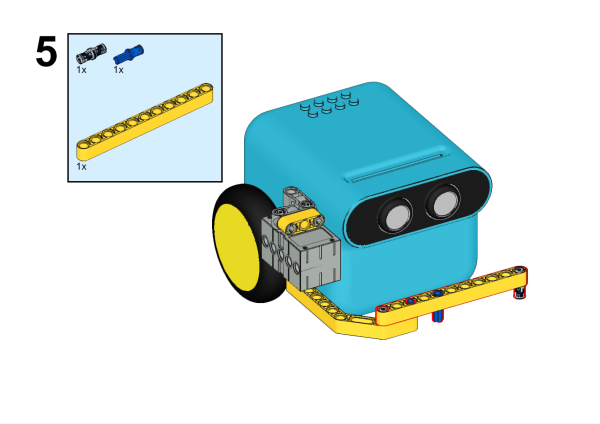
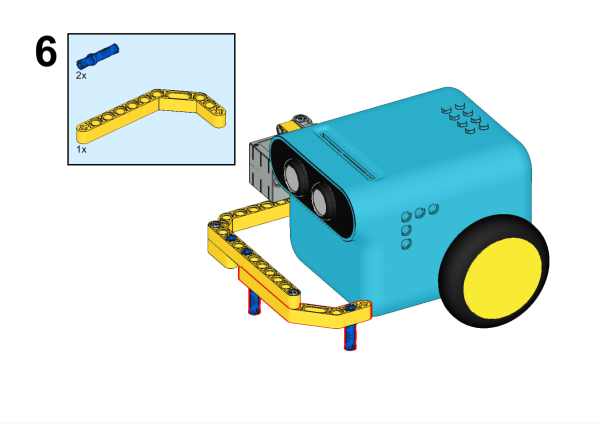
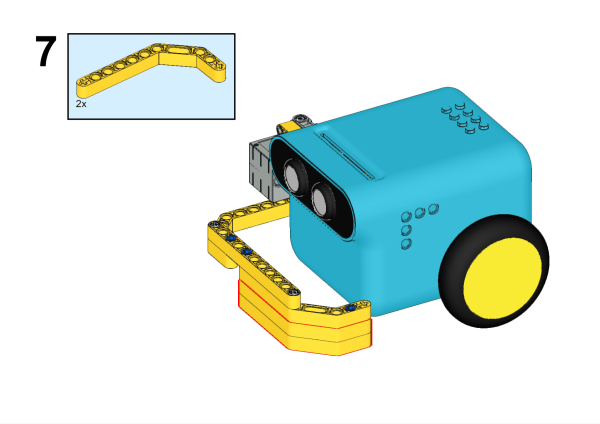
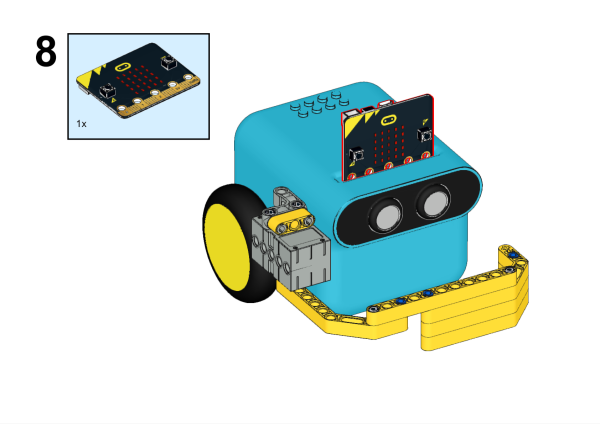
Hardware Connections
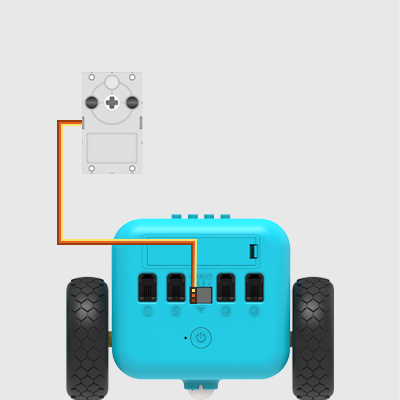
Connect the 360° servo to servo 1 port on the TPBot.
Software
Program
Click "Advanced" in the makecode drawer to see more choices.
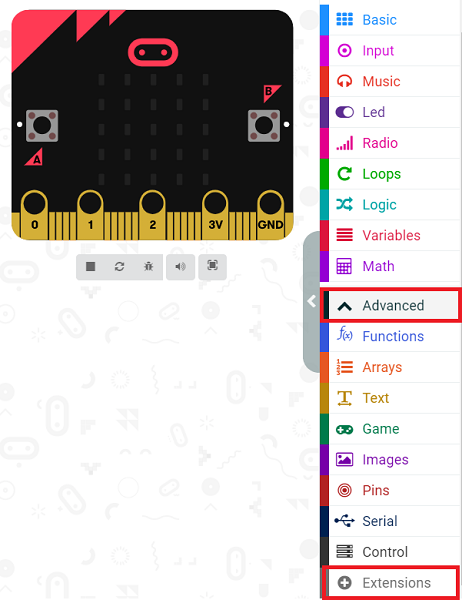
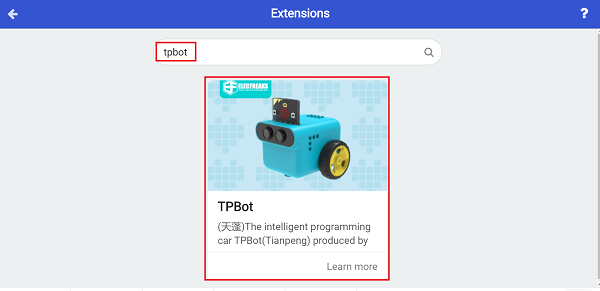
For programming the TPBot, we need to add the extensions. Click "Extensions" at the bottom of the drawer and search with tpbot in the box, then download it.
Samples program
While on start, set to show an icon and while pressing button A, make the servo connecting to S1 drive to 180 degrees; while pressing button B, set the servo connecting with S1 to ratote to 270 degrees.
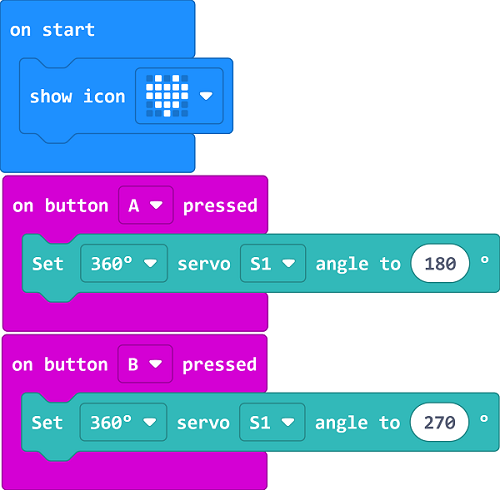
Program
Reference program: https://makecode.microbit.org/_CLmEXUVf6bbW
You may download it directly here:
Conclusion:
While pressing button A, the push rod raised up; while pressing button B, the push rod pushes to the side way.